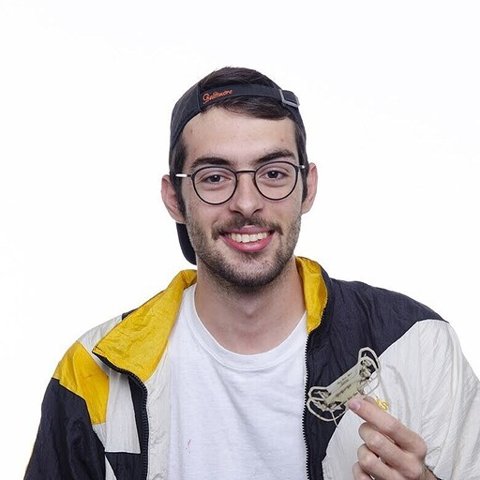
I build robots, test them, and think about how they should share our world.
Robotics engineer and PhD student at MIT CSAIL. I've worked on robots from insect-scale jumpers to humanoids, and on the ethics of putting them in front of people.
- Boston, MA
- Spanish & Swiss
- 5 languages
- Wingfoiler
About
A bit about me
I've lived in Costa Rica, Senegal, Benin, Italy, Germany, Switzerland, the UK and the US. Moving that much made me an empiricist: I don't really believe something until I've tried it myself.
I studied microengineering at EPFL in Lausanne, with an exchange year at TUM in Munich, then wrote my master's thesis in robotics at the Harvard Microrobotics Lab. I stayed on as a research fellow and led a project to build an insect-sized robot that can both walk and jump, inspired by springtails. It became my first-author paper in Science Robotics. After that I worked on the Headphone (1) at Nothing in London, and in 2024 I started my PhD at MIT.
At MIT CSAIL I work with humanoid robots: I brought up a Unitree G1 and deployed NVIDIA's GR00T model on it. As an MIT SERC Scholar I also looked at the ethics of putting models like this into real spaces. I teach too, as a TA for 6.UAR, where I advise more than 30 students a term through their first research projects.
Outside the lab I'm usually on the water wingfoiling or surfing, playing ping-pong, deep in a game of Dune: Imperium with friends, or reading philosophy and psychology.
Work
Research & engineering
-
2025 – now
Humanoid robots at the CSAIL Living Lab
MIT CSAIL. Brought up a Unitree G1 humanoid with dexterous hands and deployed NVIDIA's GR00T vision-language-action model on it: teleoperation, cameras, networking and a test rig for repeatable trials.
-
2026
Auditing a robot foundation model
MIT SERC. Evaluated a deployed GR00T model against an AI-ethics framework through a stakeholder workshop and a deployment audit. Presented as a poster at the MIT SERC Symposium.
-
2021 – 2025
A springtail-inspired walking-jumping microrobot
Harvard Microrobotics Lab. Led the project from concept through design, fabrication and high-speed testing to publication.
-
2024
Rapid manufacturing of pop-up MEMS devices
Harvard Microrobotics Lab. Design considerations for building millimeter-scale mechanisms quickly.
-
2024
Ergonomics testing for the Headphone (1)
Nothing, London. Developed new test methods and turned force measurements into design and manufacturing recommendations.
-
2025
Hardware hackathon win in Shenzhen
Scalable HCI residency. Building, factory visits and a close look at how products are made at scale.
-
2022 – 2023
Millimeter-scale surgical tools
Project 1985, Harvard. Designed and prototyped hydraulically actuated tools for a surgical-robotics start-up launched from the lab.
-
2021
Self-righting drones and propeller test benches
EPFL & Flybotix. Insect-inspired self-righting for fixed-wing drones, and a co-axial propeller test bench that cut bench costs by 75%.
-
2024
How to Make (Almost) Anything
MIT Center for Bits and Atoms. A weekly build log from Neil Gershenfeld's digital fabrication class.
Talks & teaching
Presenting and teaching
- 2026
Video interview, Embodied AI at MIT CSAIL's Living Lab
- 2026
Poster, MIT SERC Symposium
- 2025
Poster, Scalable HCI Symposium, Shenzhen
- 2023
Geneva Science and Diplomacy Anticipation Summit
- 2022
ICRA 2022 workshop on impulsive systems, Philadelphia
Teaching
- 2026
Teaching assistant, MIT 6.UAR Preparation for Undergraduate Research (two semesters)
- 2025
AI and manufacturing workshop for children, Lithuania
- 2024
Robotics tutor, TechLabs Geneva
- 2023
Guest robotics teacher, 'Iolani School, Hawaii
- 2023
Peer reviewer, IEEE Robotics and Automation Letters
Writing
Things I care about
-
In progress
How I have fun
Everyone secretly wants to jump in the water. On surfing, ping-pong, and being the person who gives everyone else the excuse.
-
In progress
Reading notes: love, freedom and the self
What I've taken from Harry Frankfurt's The Reasons of Love, Sartre's Existentialism Is a Humanism, and my detour through Jung, Freud and Adler.
-
In progress
Robots, AI and the world we're building
My view on where this is all going, from someone who has deployed a robot foundation model and audited it.
Contact
Say hello
I'm open to conversations about roles in robot evaluation, safety, deployment and technical diligence, especially in San Diego. I'm also always happy to talk philosophy, board games or where the wind is good this weekend.